HomeGet InvolvedPlan a MissionProducts & TechLandersRoversLunar Surface PowerSpace RoboticsManifestNewsCompany

Space Robotics

Astrobotic's Space Robotics team is building the robotics technology of tomorrow — from surface and subsurface robotics platforms to precision landing and hazard detection systems, found in places like the International Space Station.

Landing Navigation Exploration Robotics Software
Terrain Relative Navigation

Terrain Relative Navigation, Exploration & Hazard

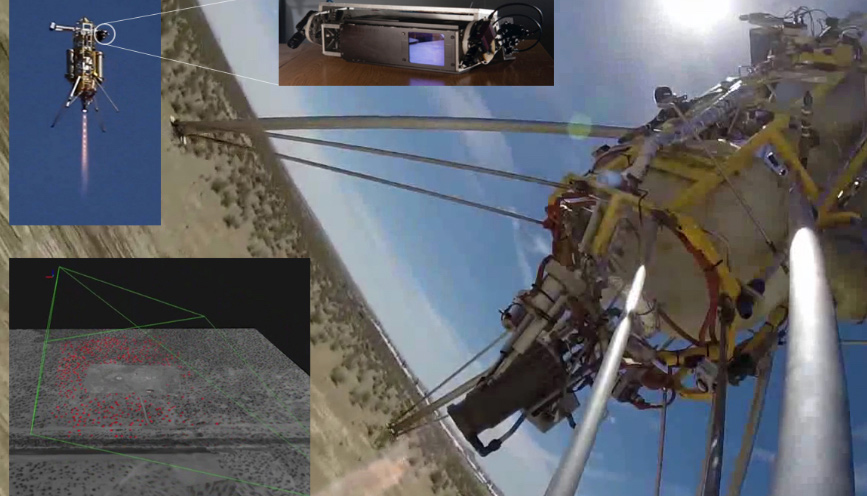
Astrobotic is developing visual terrain relative navigation (TRN) and LiDAR-based hazard detection to enable precise and safe planetary landings on the Moon, Mars, and beyond. We were the first commercial company to use TRN and hazard detection to guide a suborbital launch vehicle to a safe landing site. Our TRN system won a NASA Tipping Point contract and will fly to the Moon on our Peregrine lander. Both our TRN and hazard detection systems will be used to land NASA's VIPER rover at the south pole of the Moon on our Griffin lander.
In-Space Visual Navigation Hardware and Software

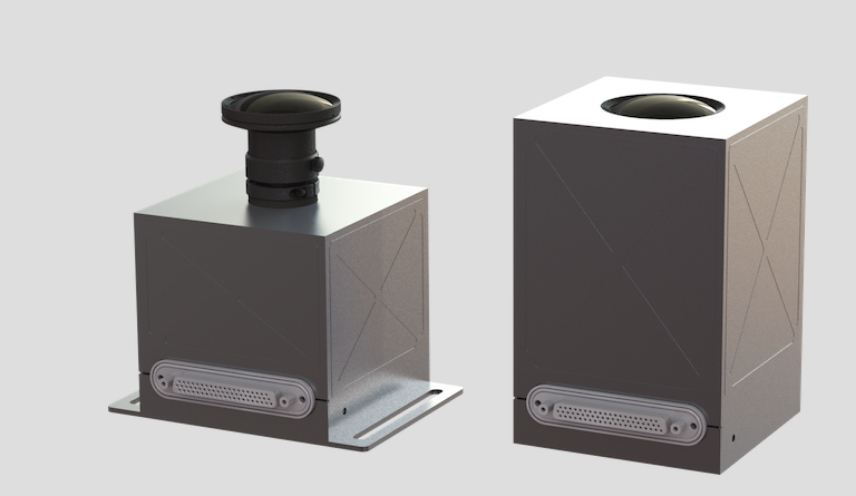
UltraNav is a compact smart camera for next-generation space missions. This low size, weight, and power system includes an integrated suite of hardware-accelerated computer vision algorithms enabling rendezvous and docking, autonomous rover navigation, and precision planetary landing. It can facilitate TRN, visual SLAM, 3D reconstruction, object recognition and tracking, and feature targeting — packaged as a standalone sensor or part of a larger navigation system.

UltraNav in-space visual navigation
Visual-Lidar-Inertial Navigation

Visual-Lidar-Inertial Navigation

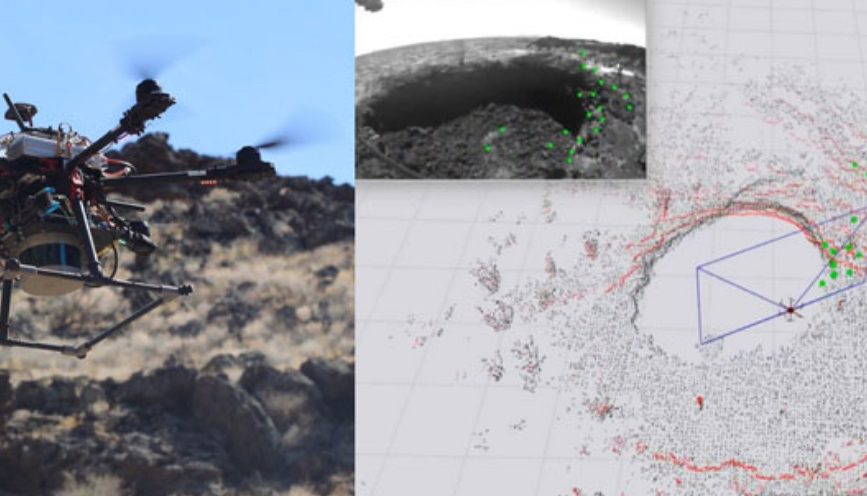
Astrobotic is developing AstroNav, a software framework for multi-sensory robotic navigation and mapping. AstroNav will enable free-flying spacecraft to rapidly explore dark, unmapped, GPS-denied environments such as lunar skylights and icy moons. It has been extensively tested in caves, tunnels, and lava tubes, leveraging factor graph-based SLAM with incremental smoothing to optimally fuse multiple sensor types in real time.

Simulation for Landing & Exploration

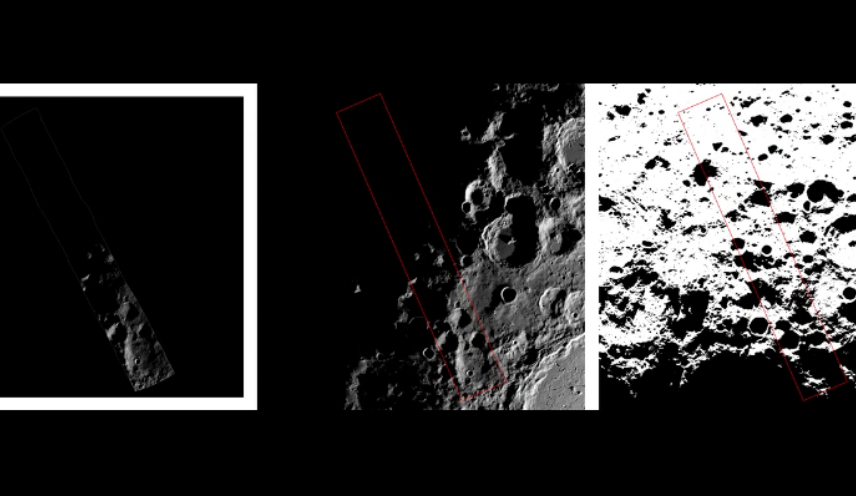
LunaRay is a physically accurate planetary renderer and suite of software tools for planning precision landings and rover traverse paths. It uses topography and ephemeris data to produce photometrically accurate renderings of lunar surface lighting for any location and time — especially useful for polar missions where long shadows change dramatically. LunaRay can also generate ground station line-of-sight and Earth elevation maps for telecommunications planning.

LunaRay landing simulation
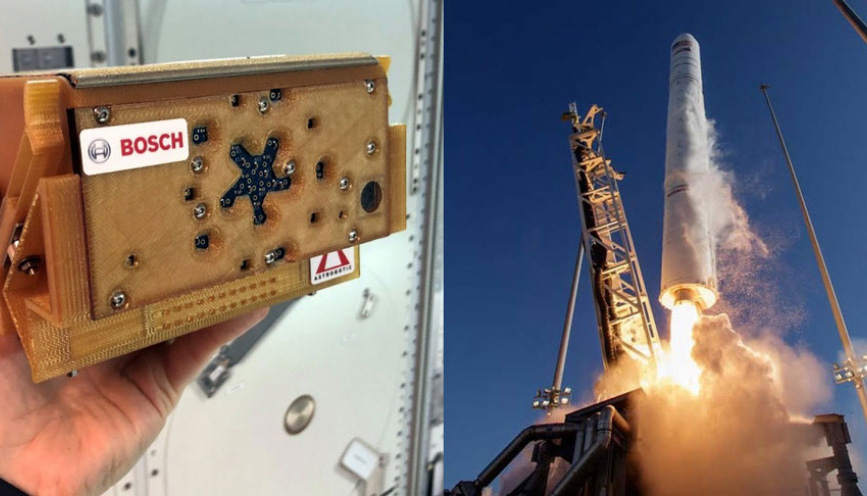
SoundSee ISS acoustic monitoring

Space Station Acoustic Monitoring

Astrobotic and Bosch Research partnered to develop SoundSee — an instrument that assisted crewmembers on the International Space Station (ISS) by flying through the station aboard NASA's Astrobee robot to acoustically monitor ISS systems and predict when maintenance was needed. SoundSee launched in 2019 and conducted its first experiments aboard the ISS in 2020, as part of a research collaboration between Astrobotic, NASA, and the ISS National Laboratory.

Surface Autonomy and Multi-Agent Robotic Missions

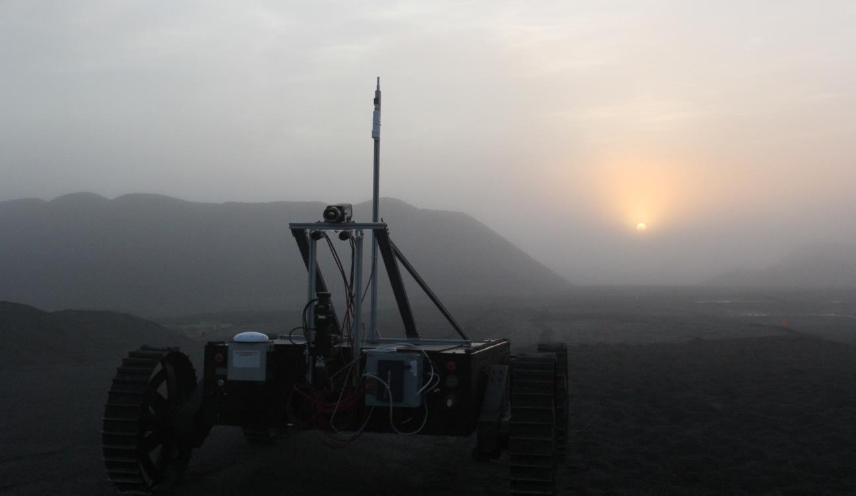
Astrobotic develops custom designs, sensor systems, and rovers for planetary surface activities such as autonomous exploration, site preparation, and resource extraction. We are developing co-localization technology for teams of rovers to enable faster exploration and greater productivity — compact sensing hardware and novel software techniques for autonomous vehicles to jointly estimate positions relative to one another and navigate more precisely.

Surface autonomy multi-agent robotics
Mission planning software

Mission Planning Software

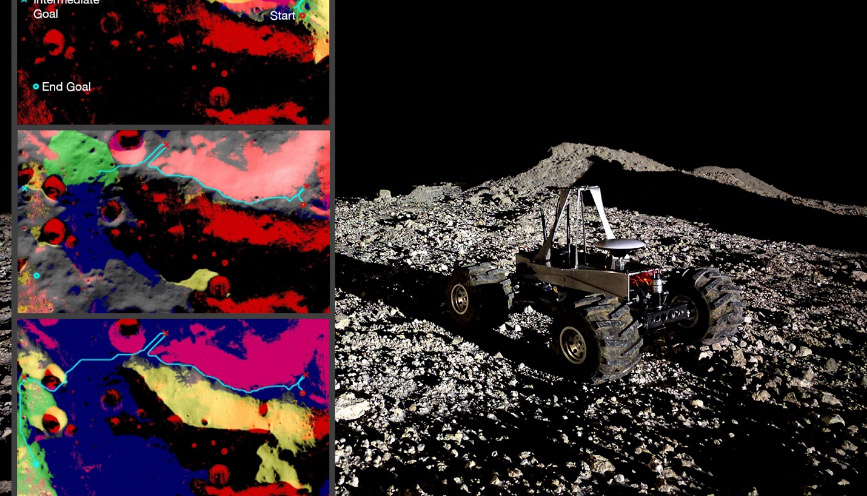
Astrobotic has developed software for planning rover missions with a graphical interface for mission engineers and scientists to explore scenarios involving different landing sites, mission durations, and safety margins. Robust route-planning algorithms consider time-varying conditions, rover capabilities, risk specifications, and the sequencing of science objectives. The software can also be applied to spatiotemporal planning tasks in mining, agriculture, and aerial surveying on Earth.

Get Involved

Plan a Mission

If you have an idea of your payloads, you're close to being ready for launch. Join us on one of our upcoming missions to space.

Plan a Mission